FAQ about the controller
Controller JUMO
All FAQ for Basics, Startup and Products Compact Controller JUMO dTRON 16.1, Compact Controller JUMO cTRON, Multi-Channel Processor and program controller JUMO IMAGO 500, Process Controller JUMO DICON 400, 500, 501 and Compact Controller JUMO dTRON 304/308/316Table of Contents
Startup
Supporting Material - Controller Optimization
System optimization made easy - controller startup software from JUMO
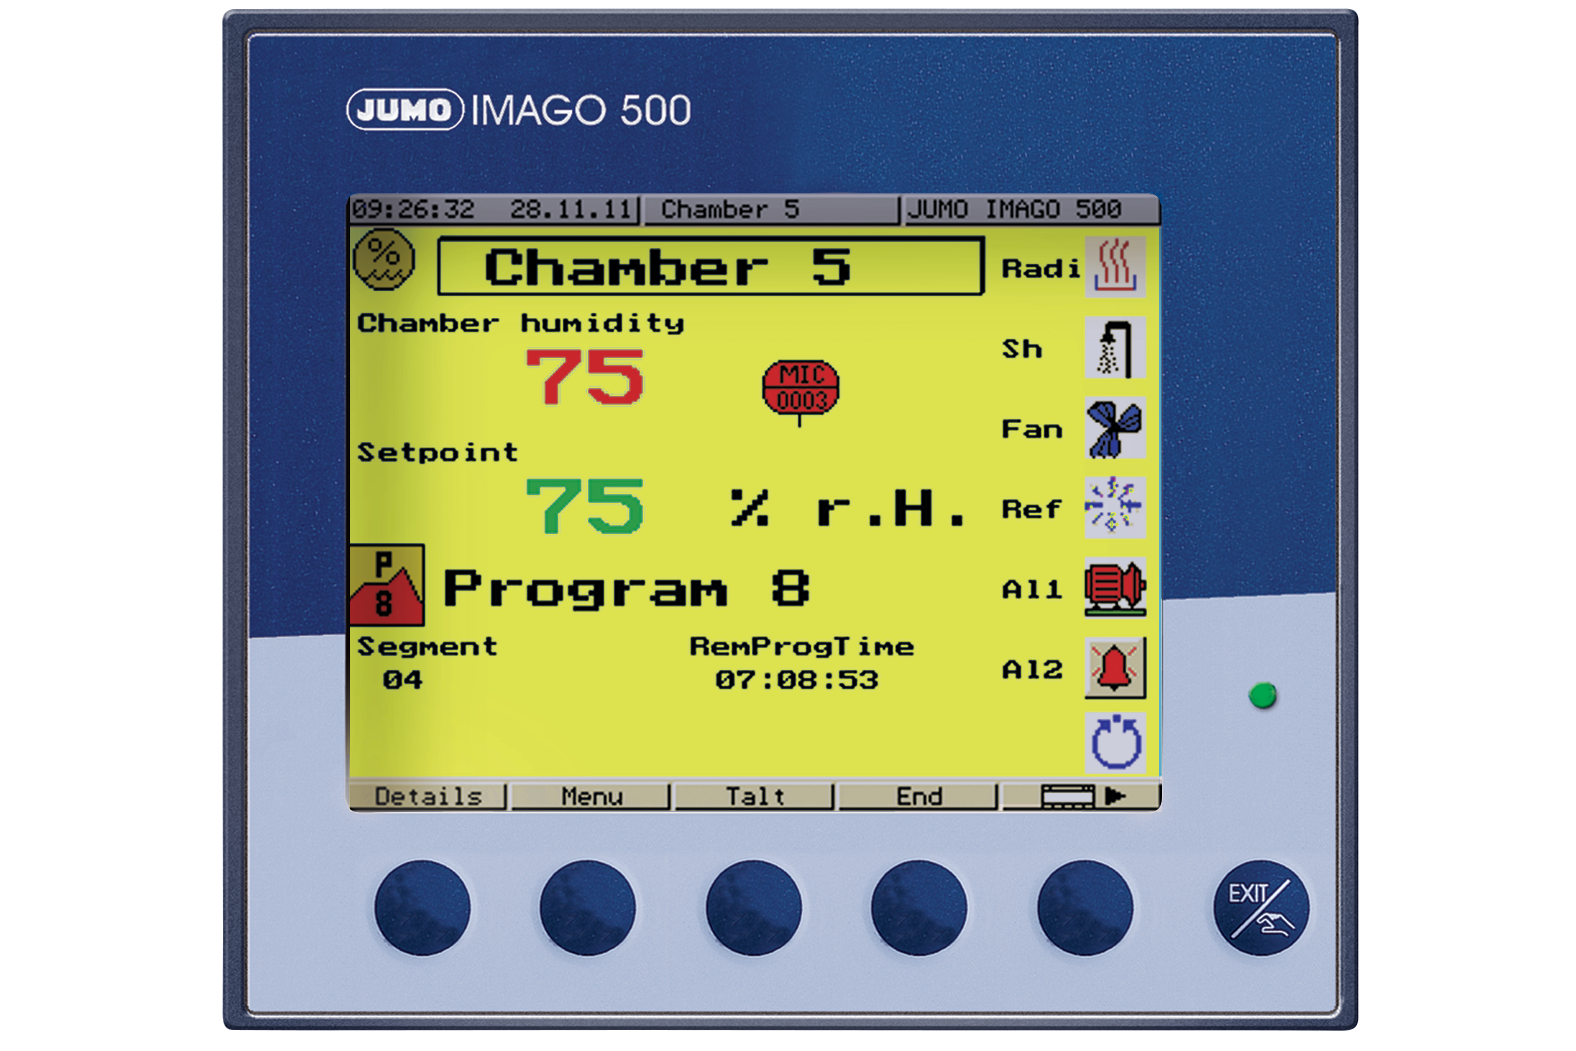
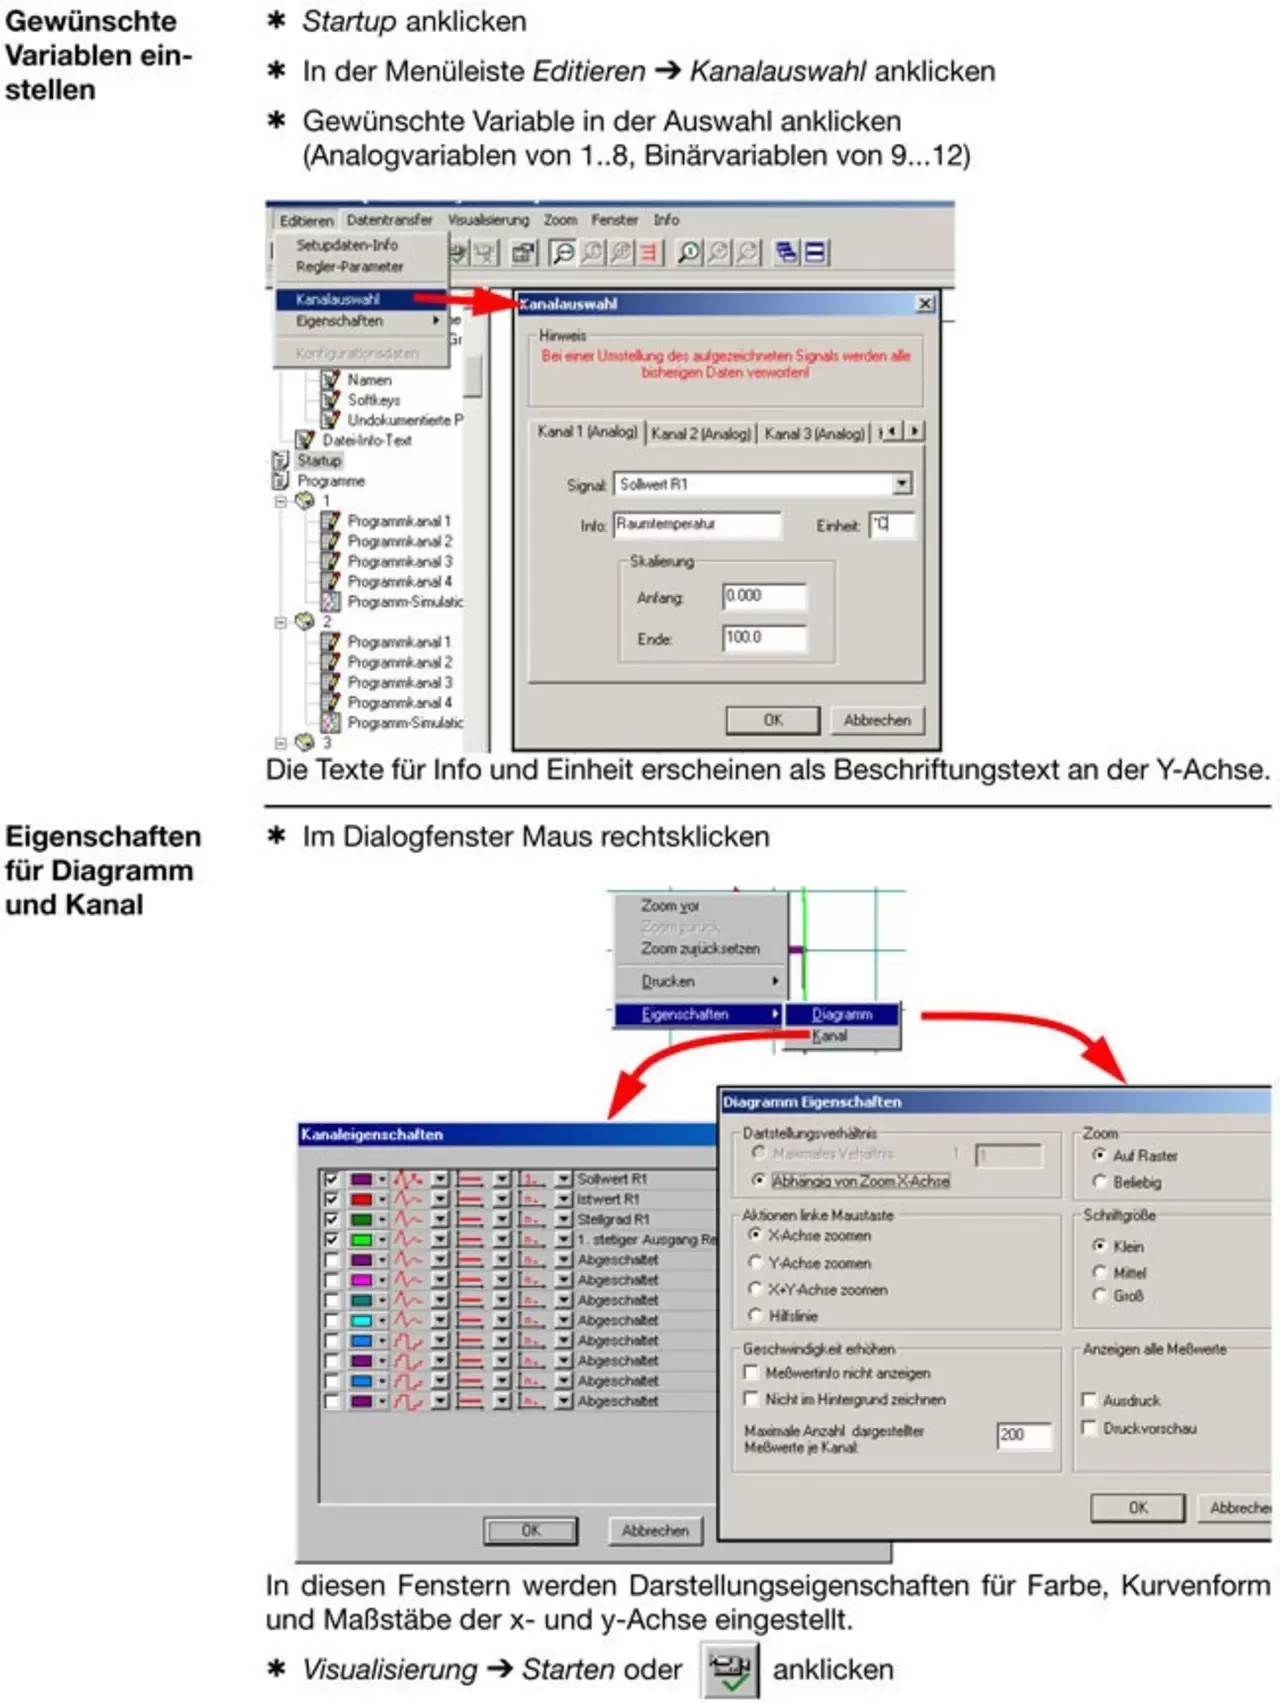
Controllers such as the JUMO IMAGO 500, JUMO DICON 500 and now the new JUMO dTRON series include a dedicated software tool in the setup program for monitoring and documenting commissioning, making operation much easier.
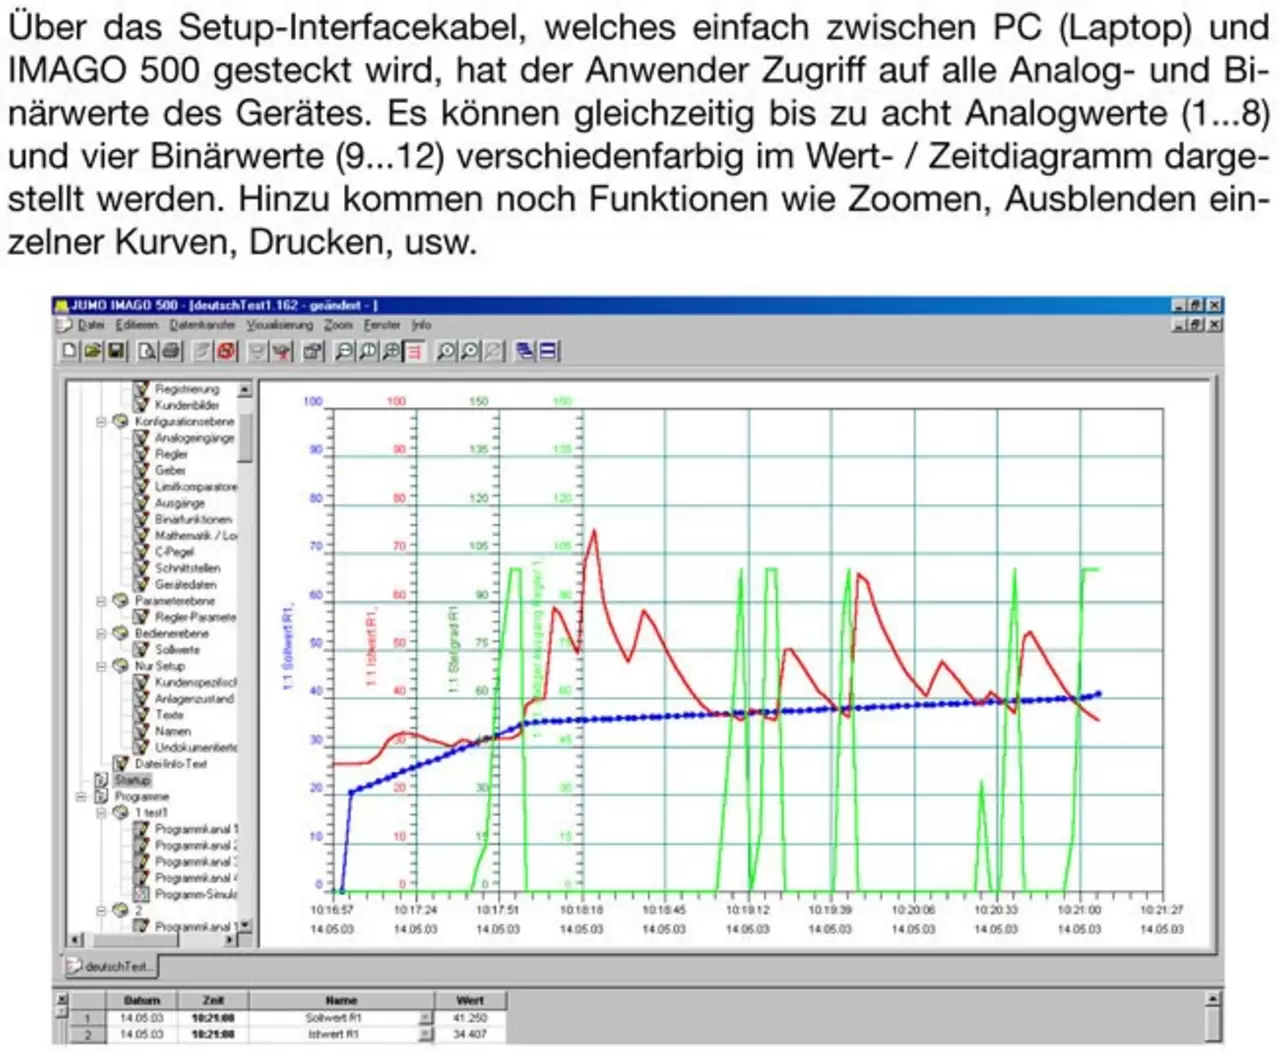
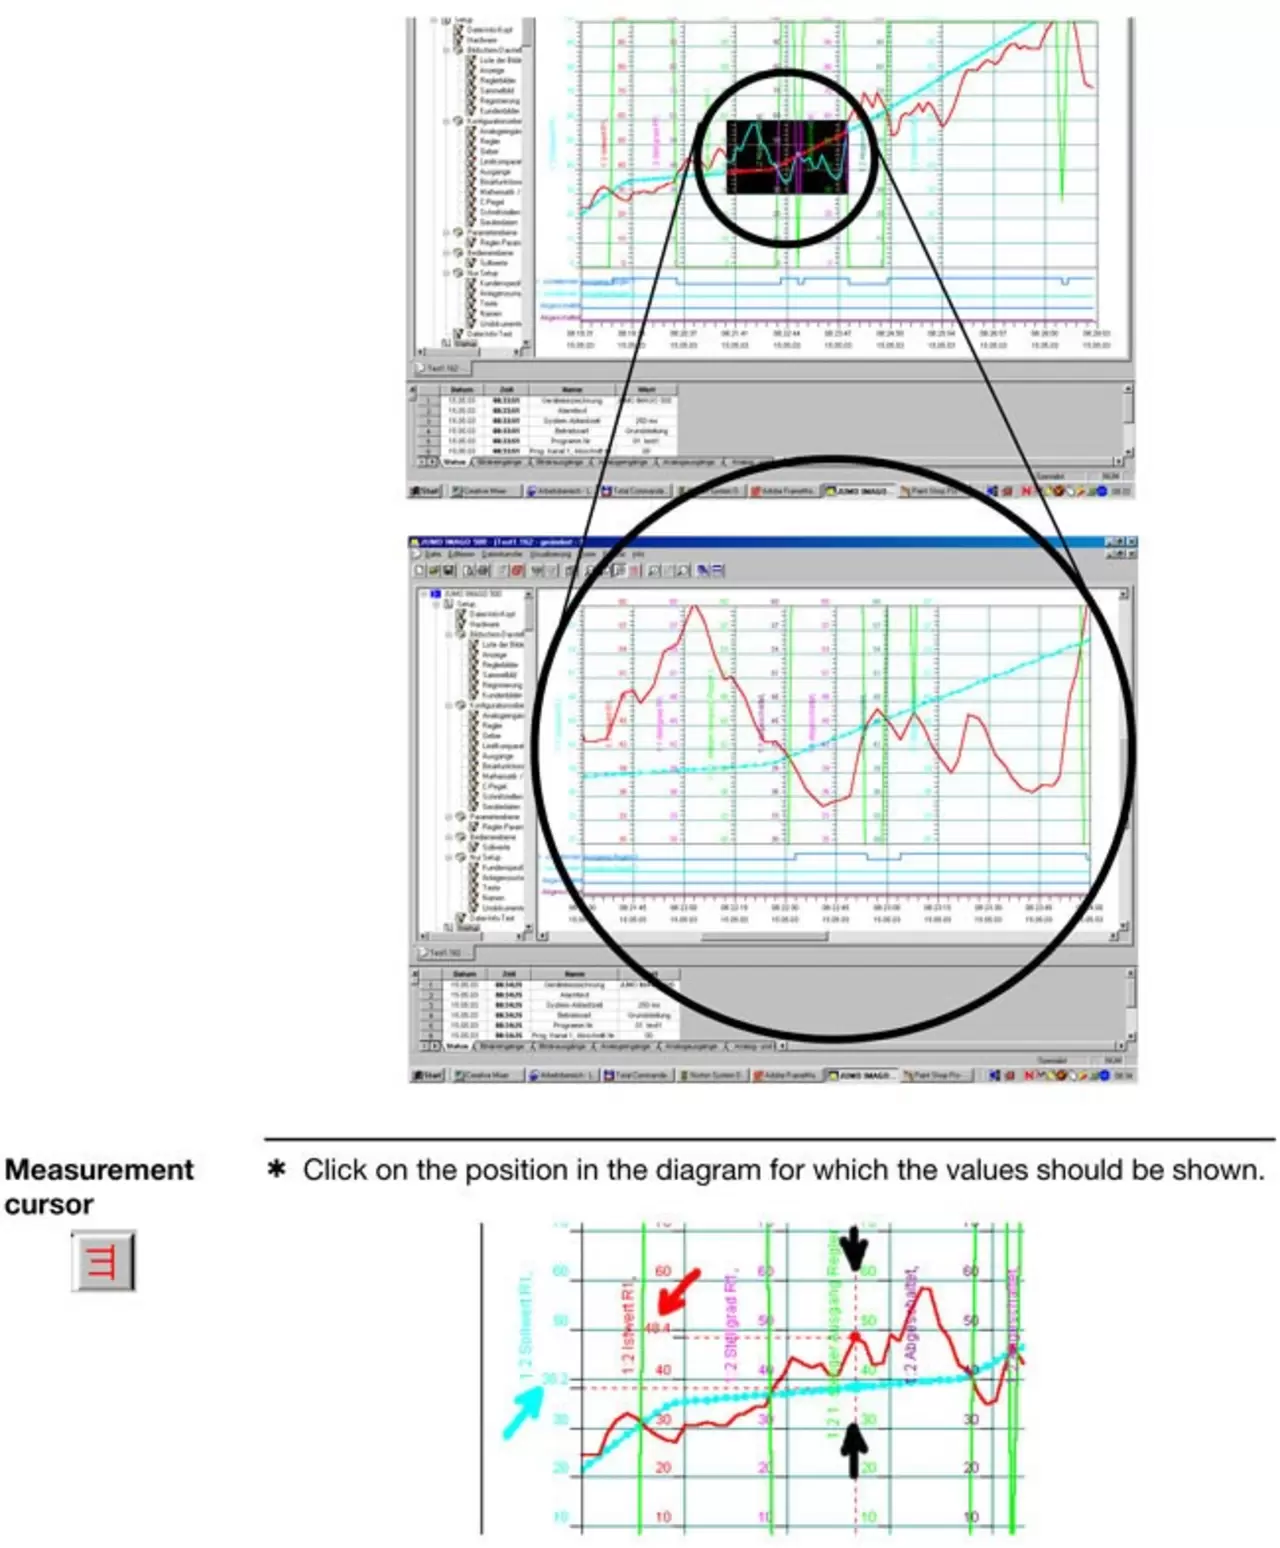
This startup software allows you to visualize and store analog and binary signals while optimizing your system.
Especially for complex processes, a visual representation of the most important process data in real time is almost indispensable for the control engineer.
All you need to optimize the system is one of the above mentioned controllers, a PC or laptop with setup software and an interface connection via a setup cable with interface RS232 or USB. This connection is required in any case for programming the setup and is therefore usually available.
Important settings such as free selection of signals for displaying individual analog and binary values in the tool, scaling, various printing options, showing or hiding individual curves, free scaling and selection of colors are all included as standard in this software tool.
The main functions of the program cover:
- monitoring and documentation of the tuning or automatic tuning phase
- generating set point step changes to determine and record reference cycle characteristics based on the cycle response
- Comparison of several different control loop results using different control parameters
- spot check of the quality of the control loop during production operation or when changing the tool
- saving these data files for quick emailing to the expert advisory group.
The program is not only useful, but also provides many other advantages, as well as economic advantages, compared to conventional process control monitoring, such as:
- No additional recorders or other peripherals required for commissioning.
- very little time required for assembly and measurement installation cable;
- lack of attachment of additional sensory equipment to the system or analog signals from the controller;
- Significant time savings thanks to a simple Plug & Play interface cable
- All important process data at a glance
- simultaneous system documentation and/or commissioning data.
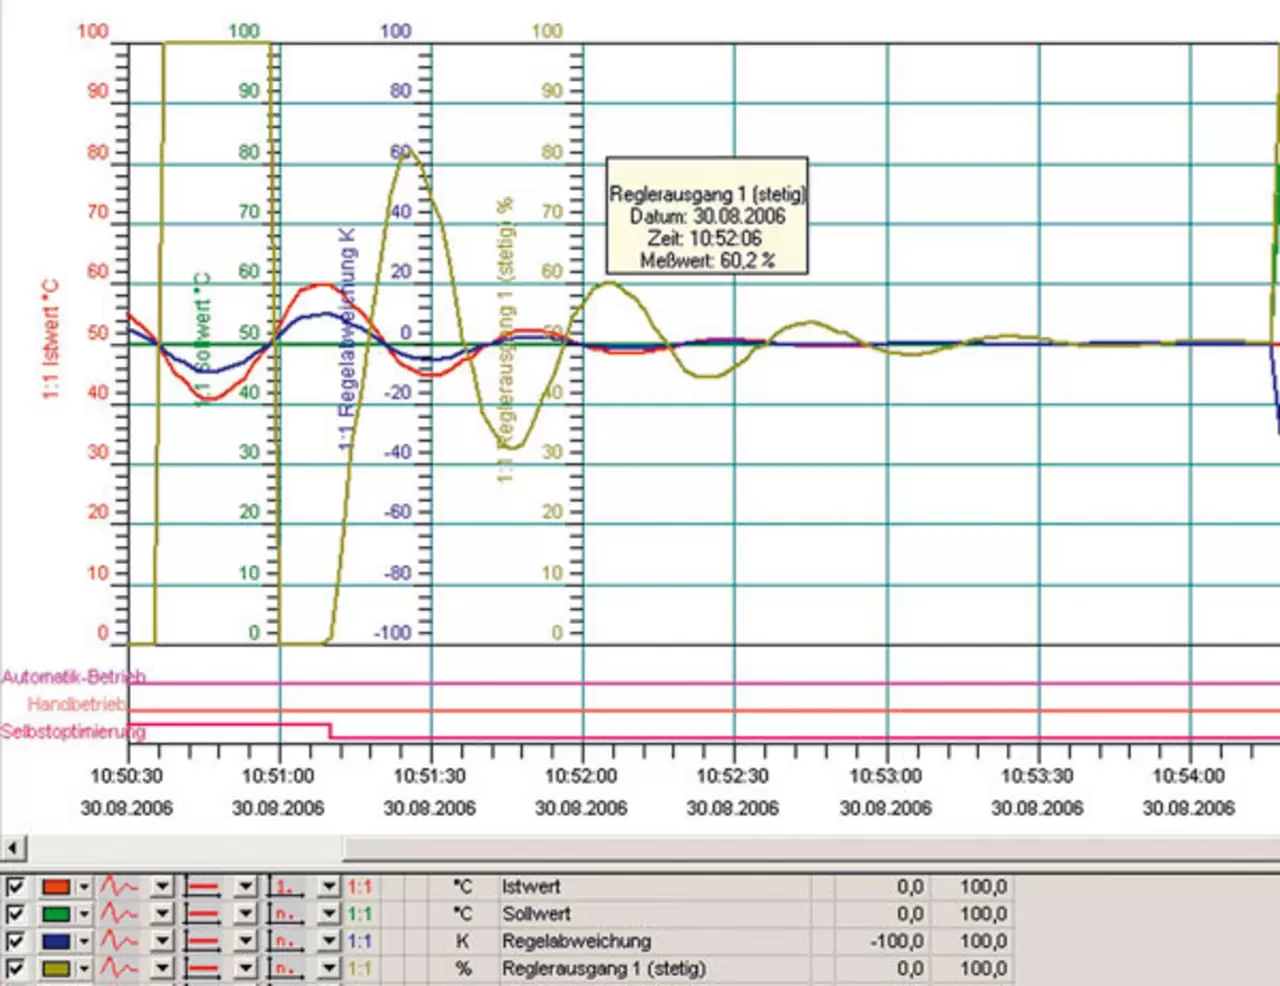
Startup Program - Operations Board - Example: JUMO IMAGO 500
Basics
General note on optimization
Controller optimization (or tuning) is tuning the controller to a given process or control cycle. Control parameters must be selected so that the most favorable control cycle response is achieved under the given operating conditions. However, this optimal response can be defined in different ways, such as reaching the set point quickly, with a slight overshoot, or a slightly longer stabilization time without overshooting. If all that is expected from the controller is a response, such as for a limit contact (no pulse operation), there is no need to find optimal settings for the proportional band, derivative time, or reset time.
In most cases, the controller can determine control parameters itself through a means of self-optimization (automation), if the process allows self-optimization. Alternatively, the optimal parameter can be determined “manually” through experiments and empirical equations (see formulas in the appendix).
When replacing controllers or with identical control settings, control parameters can also be directly accepted or entered.
After you manually configure a parameter, autotuning may no longer run as it would overwrite the settings.
Formulas for installation using the oscillation method:
Control action | |
P | XP = XPk / 0,45 |
PI | XP = XPk / 0,45T P = 0,85 ·TK |
PID | XP = XPk / 0,6Tn = 0,5 · TKTv = 0,12 · TK |
Formulas to install according to step answer:
Control action | Control loop | error |
|---|---|---|
P | XP = 3,3 · KS · (Tu/Tg) · 100 % | XP = 3,3 · KS · (Tu/Tg) · 100 % |
PI | XP = 2,86 · KS · (Tu/Tg) · 100 %Tn = 1,2 · Tg | XP = 1,66 · KS · (Tu/Tg) · 100 %Tn = 4 · Tu |
PID | XP = 1,66 · KS · (Tu/Tg) · 100 %Tn = 1 · TgTv = 0,5 · Tu | XP = 1,05 · KS · (Tu/Tg) · 100 %Tn = 2,4 · TuTv = 0,42 · Tu |
Controller characteristics/functional meaning (definitions/selection criteria)
reverse: The controller output Y is greater than 0, or the relay is energized when the process value is less than the set point (eg heating).
direct: The controller output Y is greater than 0, or the relay is energized when the process value is greater than the set point (eg cooling).
Why is the 3 state controller not suitable for actuators?
The modulating controller, like the 3-state controller, has two switching control outputs, which, however, are intended specifically for motor-driven actuators, for example for opening or closing. If a 3-state controller requires a continuous output signal to maintain a certain output level, we can see that in the case of a modulating controller, the electric actuator will remain operational. The position is reached when no signal is received from the controller.
Accordingly, the drive actuator can remain open at 60%, for example, although it is not currently controlled by the controller.
What is a digital input filter (dF)?
The digital input filter (dF) serves to dampen the input signals and affects both the display and the controller. The larger the value for "dF", the greater the damping of the input signal. An extremely high or low value can have a negative impact on control quality. In most cases the default setting of "dF" can be used for operation.
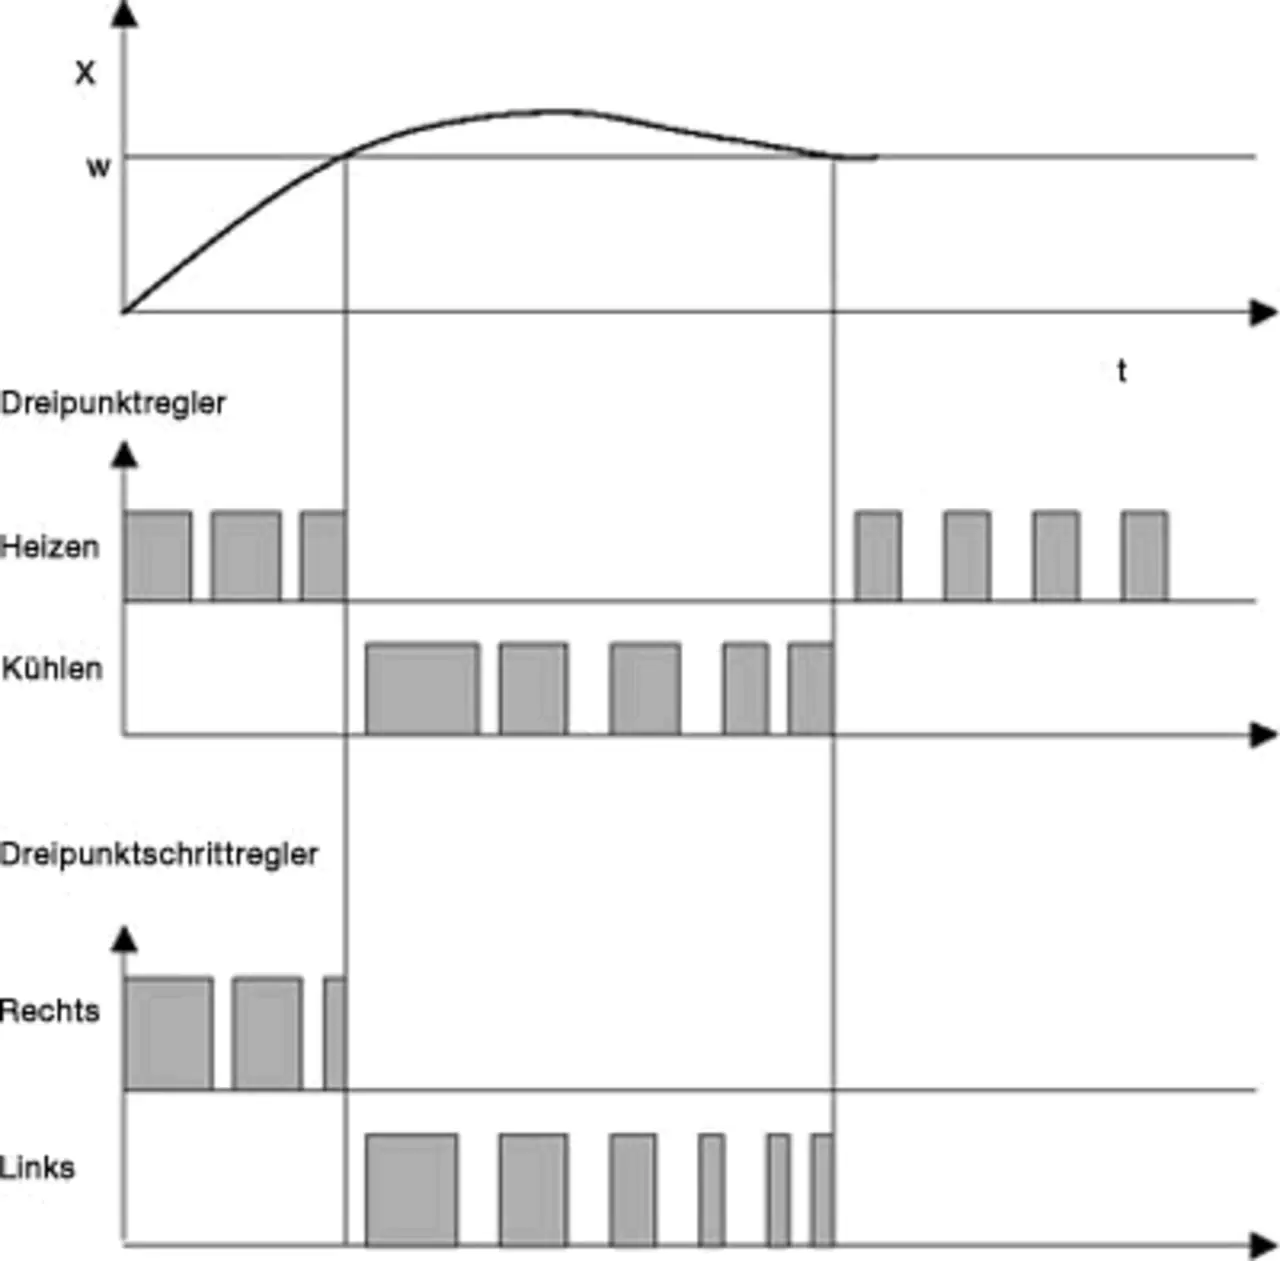
What is 3-state controller?
3-state controllers have two outputs, which can be either switching or continuous (relay contact or, for example, 4 - 20 mA). 3-state controllers are used if the control variable must be or can be influenced via two counteracting actuators.
This could be an air conditioning cabinet with a thyristor power unit for electrical heating and a solenoid valve for cooling. In this example, 3 is a state controller with a continuous (analog) output for the heating function (controller output)
- and the switching output for the cooling function (output 2 of the controller) would be the best choice.
On 3-state controllers, the proportional parameter band, reset time, derivative time and hysteresis familiar from 2-state controllers can often be set separately for both operating senses.
What is meant by controller modulation?
Modulating controllers have two switching outputs and are specifically designed for actuators that can, for example, open or close a valve valve.
Actuator drives/actuator drives that can be controlled:
AC motors, DC motors, 3-phase motor drives, hydraulic cylinders with solenoid valves, etc.
What is meant by cascade control?
Cascade control can significantly improve control quality. This applies in particular to the dynamic action of a control loop, in other words, the transition of a process variable after specified changes or disturbances.
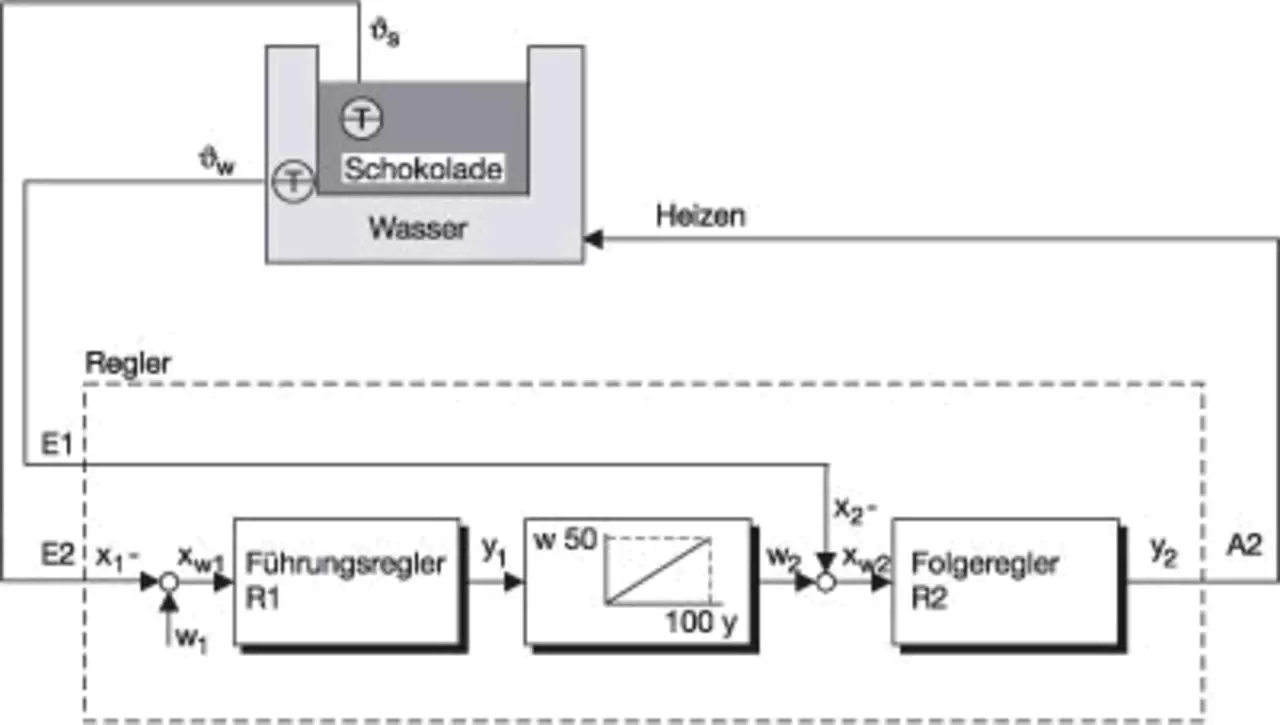
Example 1: Schematic cascade design
The chocolate needs to be heated tos = 40 °C for processing. The temperature of the chocolate should never exceed 50 °C (not even close to the heater). Therefore, it is heated in a water bath.
Cascade control is used to achieve rapid stabilization.
Controller 1 is always the master controller, and controller 2 is always the slave.
The set point for the slave controller is produced by converting the output signal.
Control output y1 converted to a given point using the process value unit x2 (here: 0 - 100 % = 0 - 50 °C).
List of characters
O2 - output 2
I1 - Analog input 1
I2 - Analog input 2
C1 - Controller 1
C2 - Controller 2
w 1 Point controller 1
w 2 Controller 2 Setpoint
x 1 Process value controller 1
x 2 Process value controller 2
x w1 - Deviation controller 1
x w2 - Deviation controller 2
y 1 - Control output 1
y 2 - control output 2; output 1 controller 2
v s Chocolate temperature
v w - Bath water temperature
Example 2: construction of a trim cascade
Two charges of chocolate should be heated to 40 °C and 50 °C. The temperature of the chocolate anywhere (not even close to the heater) should exceed the set point by more than 10 °C. Therefore, it is heated in a water bath.
Trim cascade control is used to achieve fast stabilization without overvoltage and without changing the controller configuration (output conversion) when the set point changes (batch change).
Controller 1 is always the master controller, and controller 2 is always the slave controller.
The set point for the slave controller is made by converting the output signal and adding the main set point (w).1).
In a given transformation, the control output y1 is converted to a value with process value unit w2. corresponds to the maximum permissible temperature difference (± | x)1 - w1 |; here: 0 - 100 % = from -10 to +10 °C.
O2 - output 2
I1 - Analog input 1
I2 - Analog input 2
C1 - Controller 1
C2 - Controller 2
w 1 Point controller 1
w 2 Controller 2 Setpoint
x 1 Process value controller 1
x 2 Process value controller 2
x w1 - Deviation controller 1
x w2 - Deviation controller 2
y 1 - Control output 1
y 2 - control output 2; output 1 controller 2
v s Chocolate temperature
v w - Bath water temperature
Example 2: construction of a trim cascade
Two charges of chocolate should be heated to 40 °C and 50 °C. The temperature of the chocolate anywhere (not even close to the heater) should exceed the set point by more than 10 °C. Therefore, it is heated in a water bath.
Trim cascade control is used to achieve fast stabilization without overvoltage and without changing the controller configuration (output conversion) when the set point changes (batch change).
Controller 1 is always the master controller, and controller 2 is always the slave controller.
The set point for the slave controller is made by converting the output signal and adding the main set point (w).1).
In a given transformation, the control output y1 is converted to a value with process value unit w2. corresponds to the maximum permissible temperature difference (± | x)1 - w1 |; here: 0 - 100 % = from -10 to +10 °C.
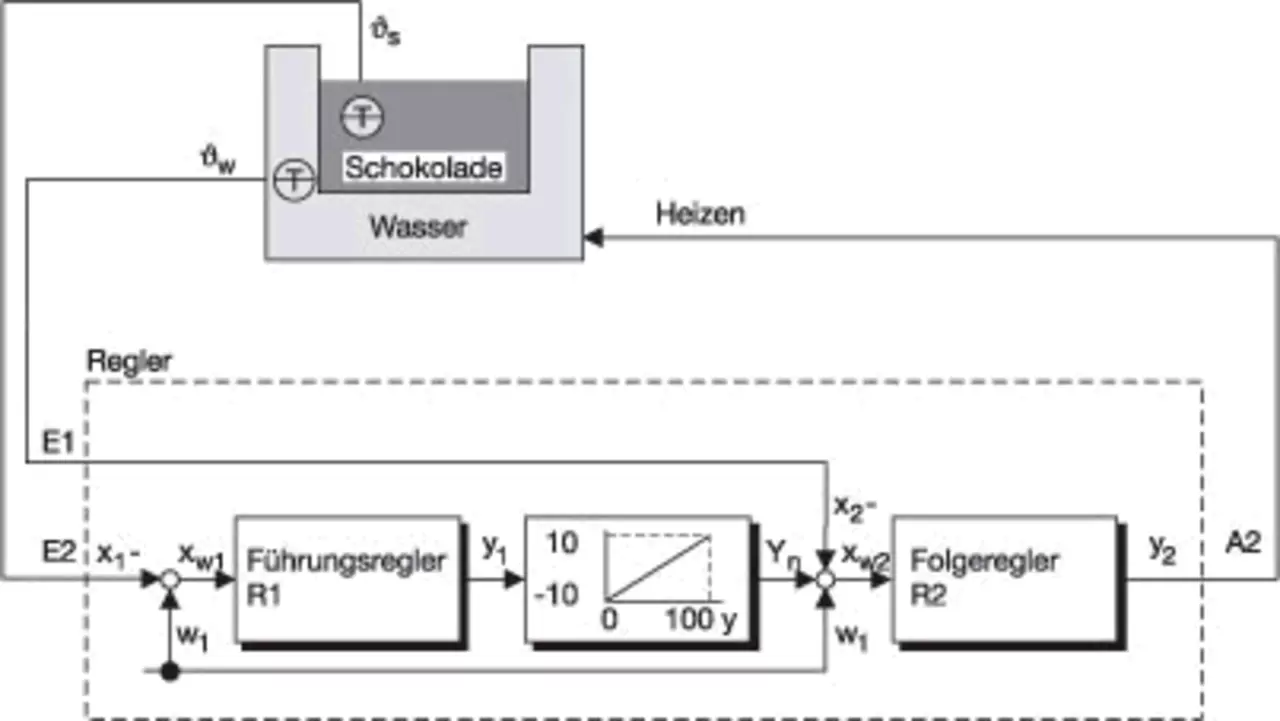
List of characters
O2 - output 2
I1 - Analog input 1
I2 - Analog input 2
C1 - Controller 1
C2 - Controller 2
w1 - Point controller 1
x1 - process value controller 1
x2 - process value controller 2
xw1 - deviation controller 1
xw2 - deviation controller 2
y1 - Control output 1
y2 - Control pin 2; output 1 o controller 2
vs - chocolate temperature
VW - water bath temperature
O2 - output 2
I1 - Analog input 1
I2 - Analog input 2
C1 - Controller 1
C2 - Controller 2
w1 - Point controller 1
x1 - process value controller 1
x2 - process value controller 2
xw1 - deviation controller 1
xw2 - deviation controller 2
y1 - Control output 1
y2 - Control pin 2; output 1 o controller 2
vs - chocolate temperature
VW - water bath temperature
What is meant by contact distance?
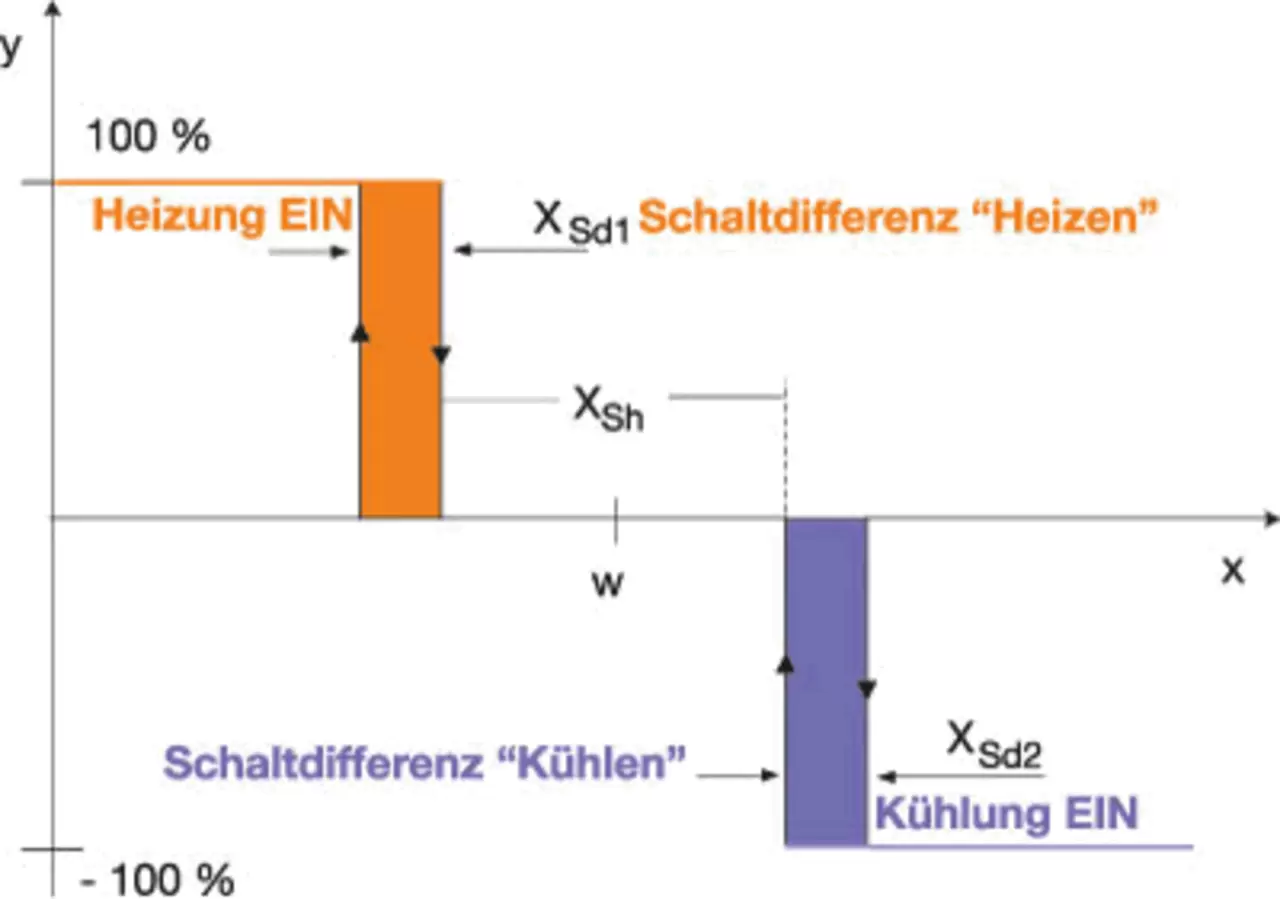
If the process variable changes within a fixed interval around a given point - the Xsh pin interval - then neither output is active. Exception: 3 states of controllers with components I and D. Within the contact interval, only the proportional component is inactive.
This contact interval is necessary to prevent constant switching between two manipulating variables, such as heating and cooling registers, when the control variable is unstable. Contact interval is also commonly referred to as dead band. Too little dead space can waste energy in the plant.
What is meant by reboot time?
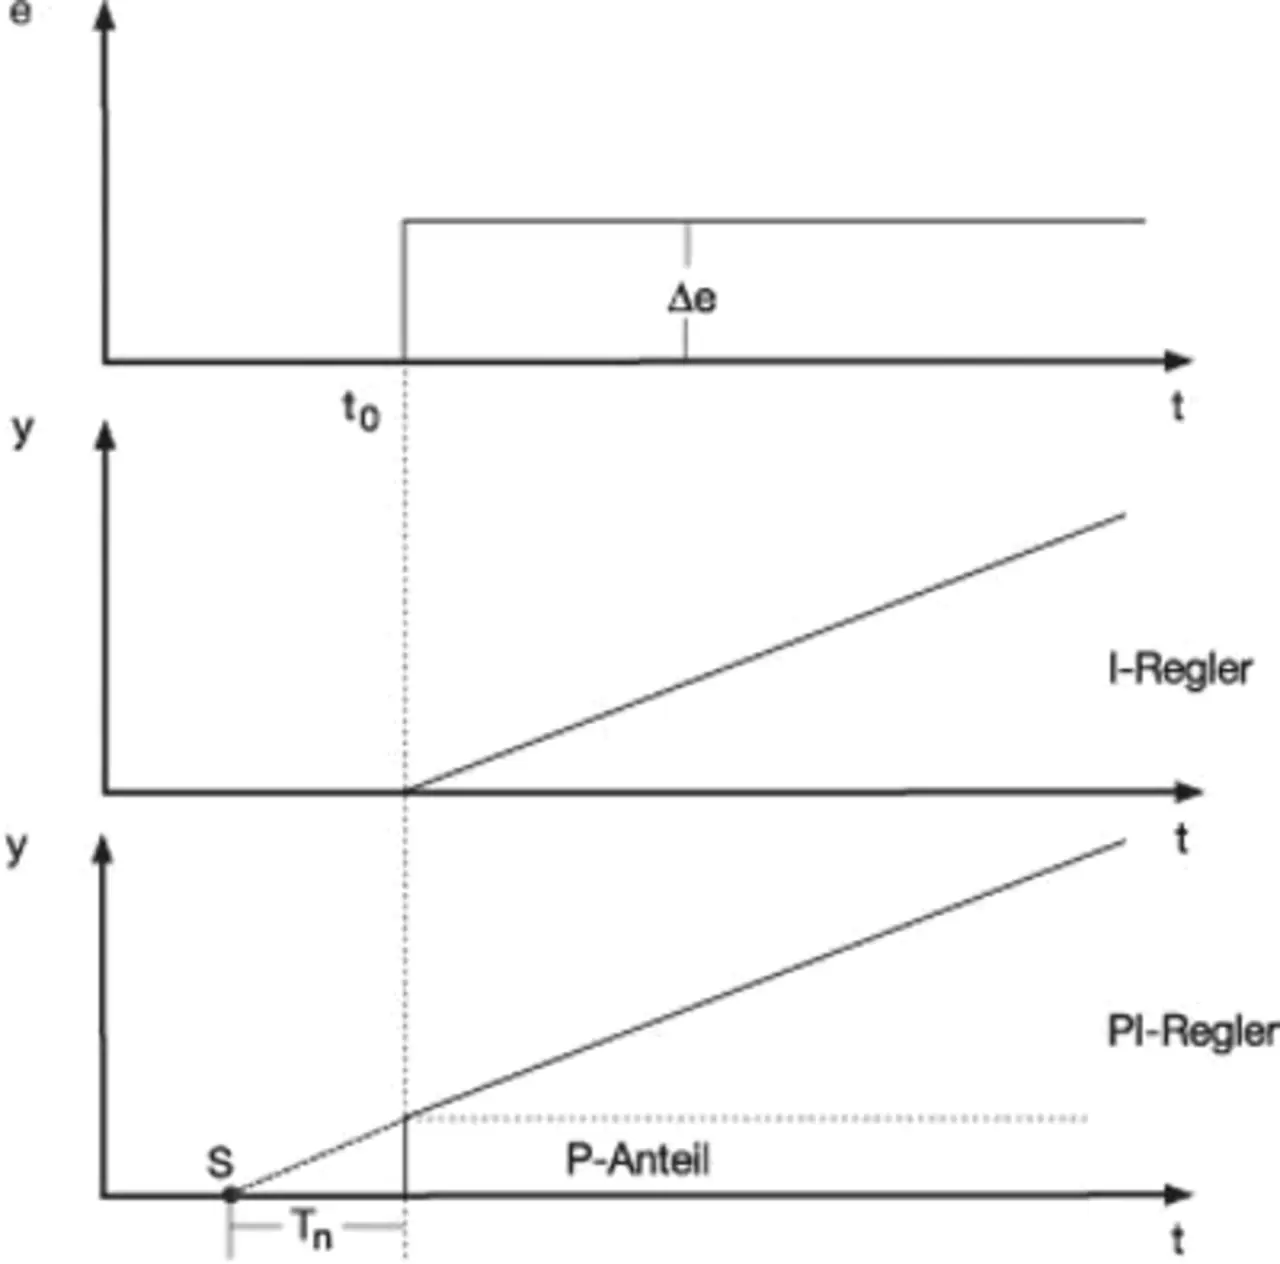
The I component of the controller output has the effect of continuously changing the manipulating variable until the process value reaches the set point.
As long as the control deviation is present, the manipulation variable is integrated up or down. The longer the control deviation continues to be present in the controller, the greater the integral effect on the manipulation variable. The larger the control deviation and the shorter the reset time, the more pronounced (faster) the effect of the I component.
Component I provides stabilization of the control loop without permanent deviation from control. The reset time is a measure of the effect of the duration of control deviation on control action. A longer reset time means that component I is less efficient and vice versa. During a given time Tn (in seconds), a change in the manipulating variable is added, which is produced by the P-component (xp or pb). Accordingly, there is a fixed relationship between the P component and the I component. A change in the P component (xp) also means a changed time response at a constant value for Tn.
What does proportional band (Xp1, Xp2) mean?
In a pure proportional controller (P controller), the manipulation variable (controller output Y) is proportional to the control deviation in the proportional band (Xp). The controller gain can be matched to the process by changing the proportional band. If a narrow proportional band is selected, a small deviation is sufficient to achieve 100 percent output, i.e. the gain increases as the proportional band (Xp) decreases. The controller's response to a narrow proportional band is faster and more pronounced. A proportional band that is too narrow will cause the control loop to oscillate. Any change in the proportional band will also affect the I and D action of the PID-controller to the same extent.
If proportional band is set to zero, the controller is ineffective. This means that the controller operates solely as a limit contact. The selected hysteresis or differential switching is effective; the settings for the derivative time and reset time are, however, not taken into account.
For all controller types, with the exception of the controller with the 3-state (double point), only the proportional band Xp1 is relevant. When using only 3-state controllers, separate settings for the proportional band (for both operating senses) are required (for example, Xp1 for heating and Xp2 for cooling).
What is meant by differential/hysteresis switching?
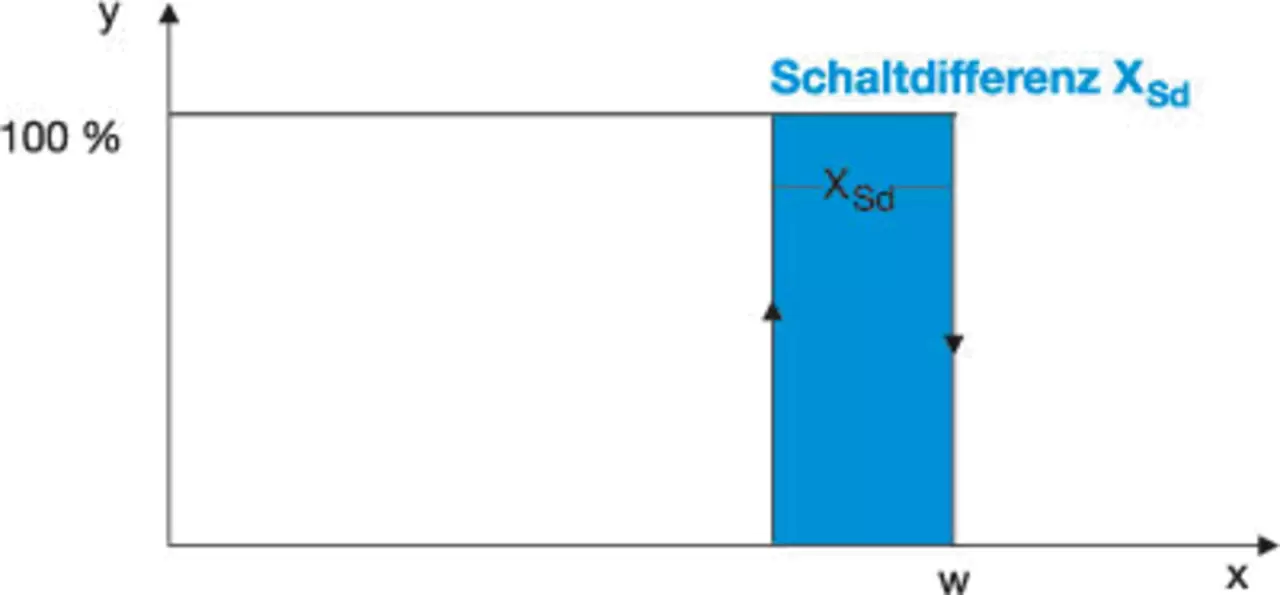
The switching differential is also called hysteresis and only applies to switching controllers with proportional band = 0.
For controllers with reverse operating value (such as heating control), the standard answer is as follows:
The shift differential is below the set point. This means that the controller switches off exactly when the set point is exceeded. It is only turned on again when the process value has fallen below the switch-on point, which lies below the set point by the amount of the switching differential.
On controllers with a direct operating meaning (eg cooling), the switching differential usually lies above the set point. As for controllers with reverse operating meaning, the switch-off point is exactly at the specified point. However, it is switched on again above the set point, shifted by the amount of the switching differential.
What does actuator running time (tt) mean?
The actuator stroke time is a variable provided by the actuator drive and is therefore only relevant to modulating controllers or proportional (continuous) controllers with an integral actuator drive.
The time it takes for the actuator to move once over the entire useful range of manipulation is set under the actuator stroke time.
The drive running time cannot be determined by self-optimization (automation). It should always be set before optimization.
The drive stroke time provides the controller with information about the action of the drive pulses. With a drive stroke time of 20 seconds, for example, the percentage change in the manipulating variable, while the driving impulse, is significantly greater than for a drive with a stroke time of 100 seconds, for example.
When selecting or measuring actuator drives, it must be taken into account that short stroke times, say less than 10 seconds, will lead to large steps of the manipulating variable, and hence to reduced control accuracy. If, for example, we assume that 0,5 seconds is the shortest actuation pulse time, a stroke time of 10 seconds will result in only 20 actuation steps. This will mean that the manipulating variable can only be changed in 5% steps.
Actuator drives with very long stroke times can, however, be disadvantageous in terms of dynamics, since the manipulating variable can only be changed relatively slowly by the control action. In actual operation, however, problems caused by stroke times that are too short occur more often than problems caused by stroke times that are too long.
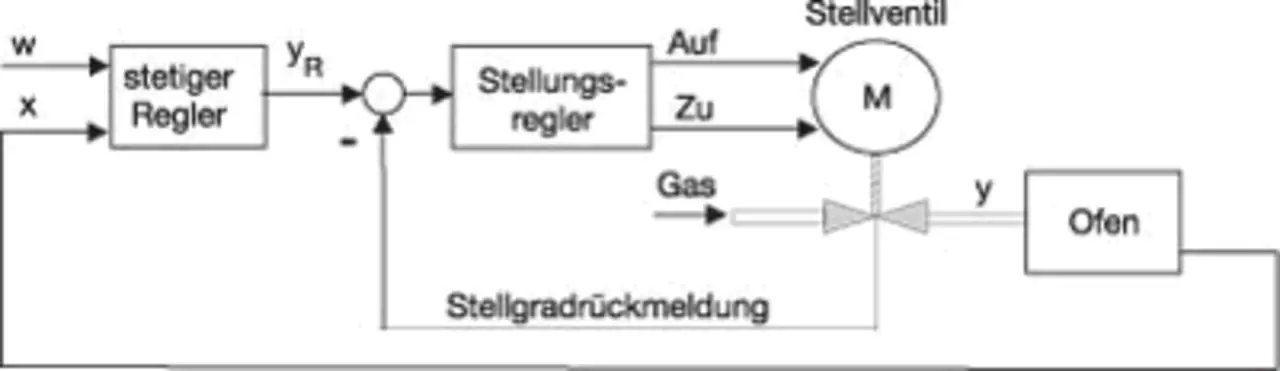
What is meant by proportional controller with integral drive?
The short form "acting controller" is used to describe a "proportional controller with an integral actuator drive." Unlike a modulating controller, a drive feedback signal is required for the actuating controller.
The actuation controller controls clockwise or counterclockwise movement of the motorized actuator via 2 switch outputs.
The position of the motorized actuator is recorded and compared with the manipulating variable (yR) of the proportional controller.
What is meant by derivative time?
The intensity of the D component (differential component) can be set through derivative time. Controller component D with action PID or PD reacts to the rate of change of the process value.
As the set point is approached, the D component acts as a brake, thereby preventing the control variable from exceeding the set point.
Basically, component D has the following effects:
As soon as the control variable changes, the D component reacts to this change.
For a controller with reverse operating value (i.e. heating) this would mean, for example,
- If the control variable decreases as a result of a process disturbance, component D forms a positive manipulation variable that counteracts the decrease in the control variable.
- If the control variable increases as a result of a process disturbance, component D forms a negative manipulation variable that counteracts the increase in the control variable.
- The damping effect increases with the size of the derivative time setting (value in seconds).
What is 2-state controller?
The 2-state controller (ON/OFF-controller) switches the output when the set point is reached. If the value falls below the set point within a certain adjustable tolerance (xsd, switching differential, hysteresis), the output is switched on again. Therefore it has only two switching states. It is used in temperature control applications where heating or cooling is only turned on or off.
The 2 state controller with dynamics can, however, also operate with components P, I or D.
What does cycle time (Cy) mean?
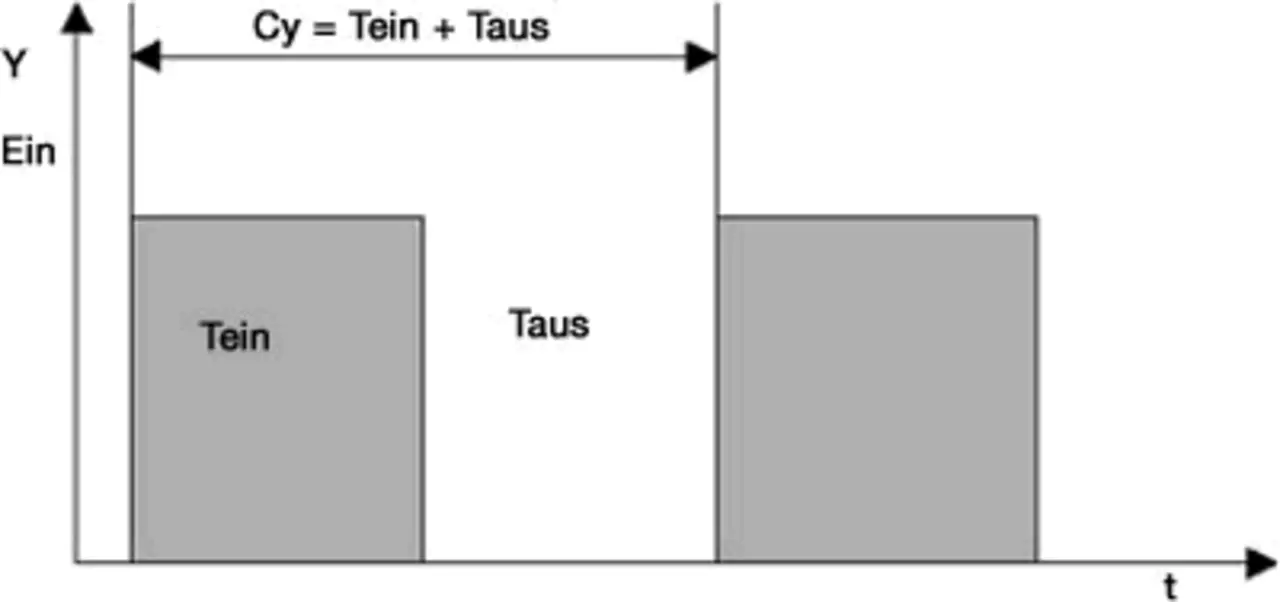
The switching cycle time is specified in seconds and defines the period during which a complete switching cycle consisting of on and off times occurs.
Generally, the cycle time should be chosen in such a way that the actual control process can still be smoothed out. The switching frequency must always be taken into account.
The reaction is best reset manually so that the direct effect of the manipulating variable on cycle time can be controlled. With the manipulating variable 50 % “Tone” and “Toff” are equal. If the manipulating variable is changed, this relationship changes accordingly.
The reaction is best reset manually so that the direct effect of the manipulating variable on cycle time can be controlled. With the manipulating variable 50 % “Tone” and “Toff” are equal. If the manipulating variable is changed, this relationship changes accordingly.
PID-controller - what you need to know